by
In this Robot Operating System (ROS) Version 2 tutorial, or ROS 2 tutorial, whose link is given here, we explain the basics of ROS2 by using the Turtlesim simulation. In particular, this tutorial is developed for the ROS2 Jazzy Jalisco version of ROS2. Jazzy Jalisco is the most recent version of ROS2. However, with small modifications, everything explained in this tutorial works for other versions of ROS2
Turtlesim is a simple model and simulation of a 2D mobile robot. This example is used to illustrate the main ideas and concepts of ROS 2. Consequently, if you are completely new to ROS, you should start with this example. Later on, you can build your own mobile robot and apply the learned concepts to the real hardware.
In this tutorial, we explain
- How to start nodes in ROS2
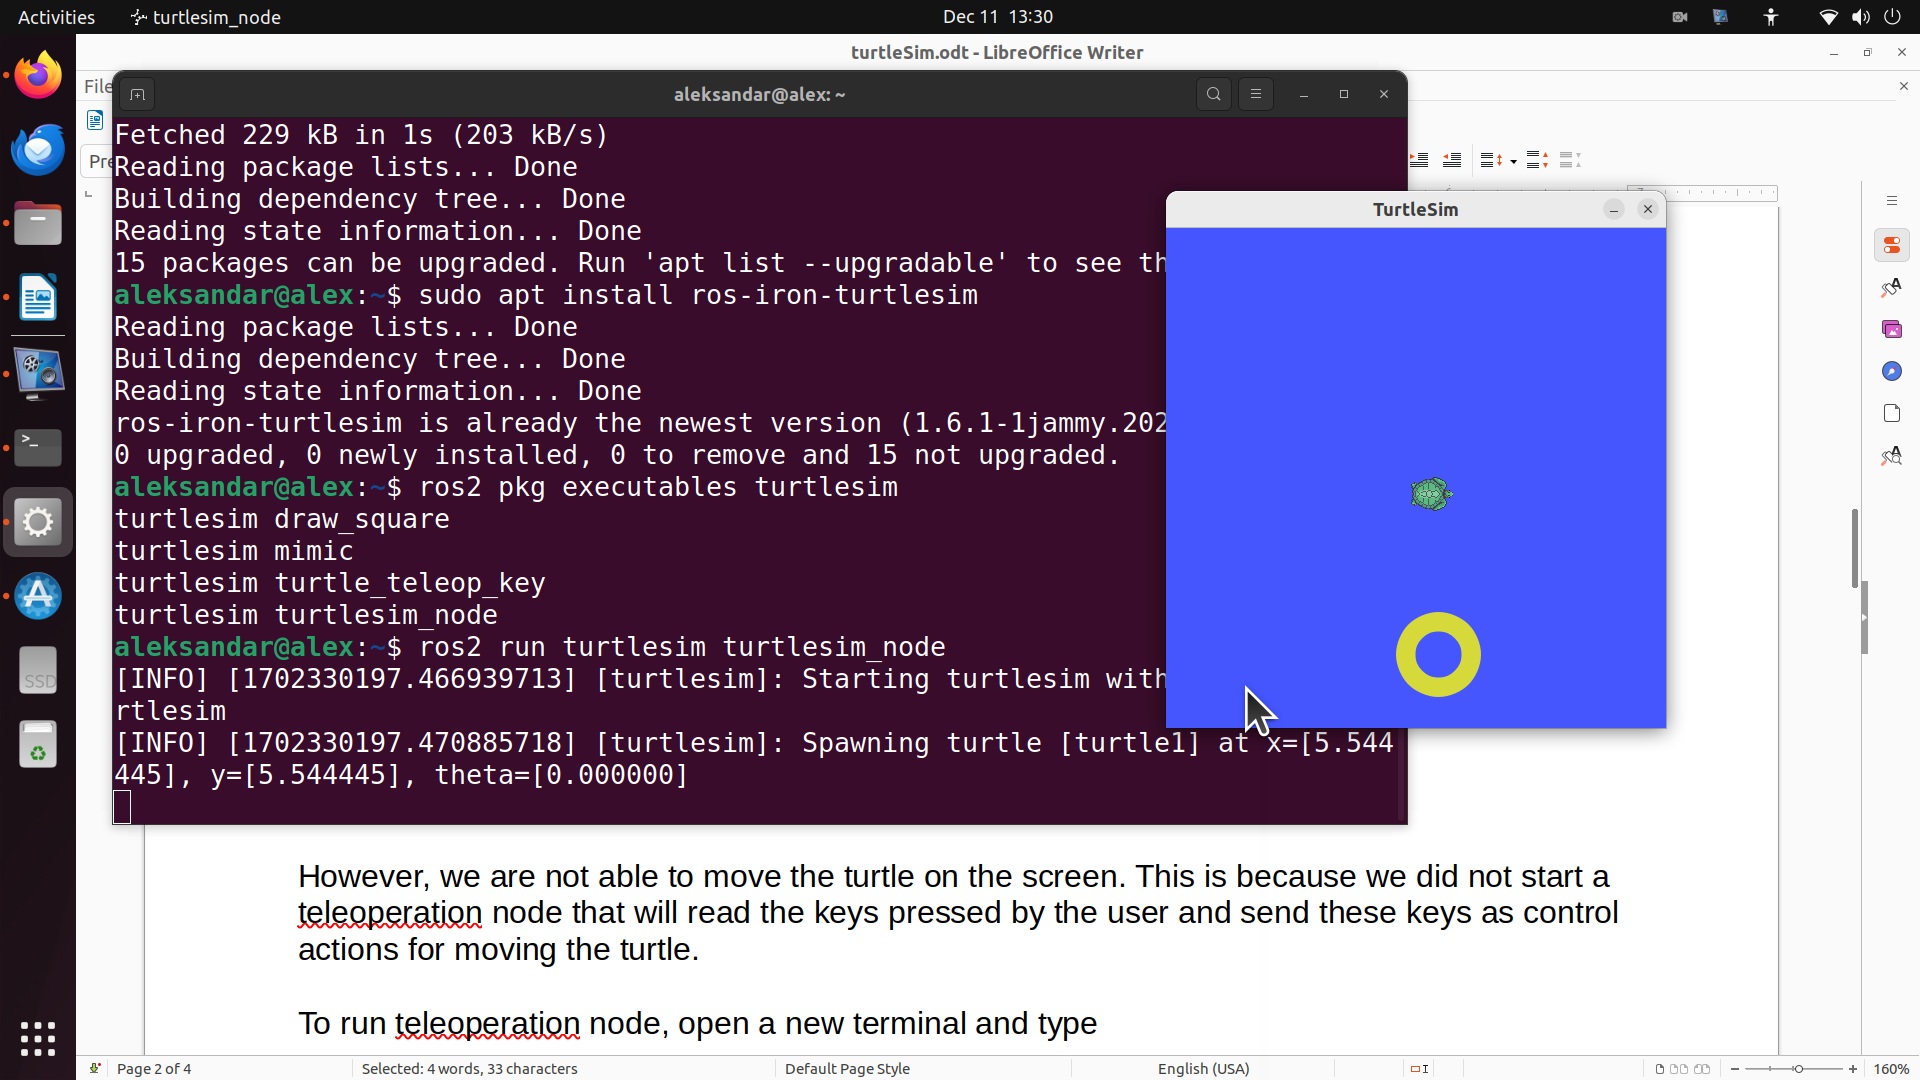
- How to start a Turtlesim node in ROS2
- How to start a teleop (short for teleoperation) node is ROS2 that will enable us to control the Turtlesim in ROS2
- How to obtain information about the nodes, topics, services, and parameters that currently running in the ROS2 system.