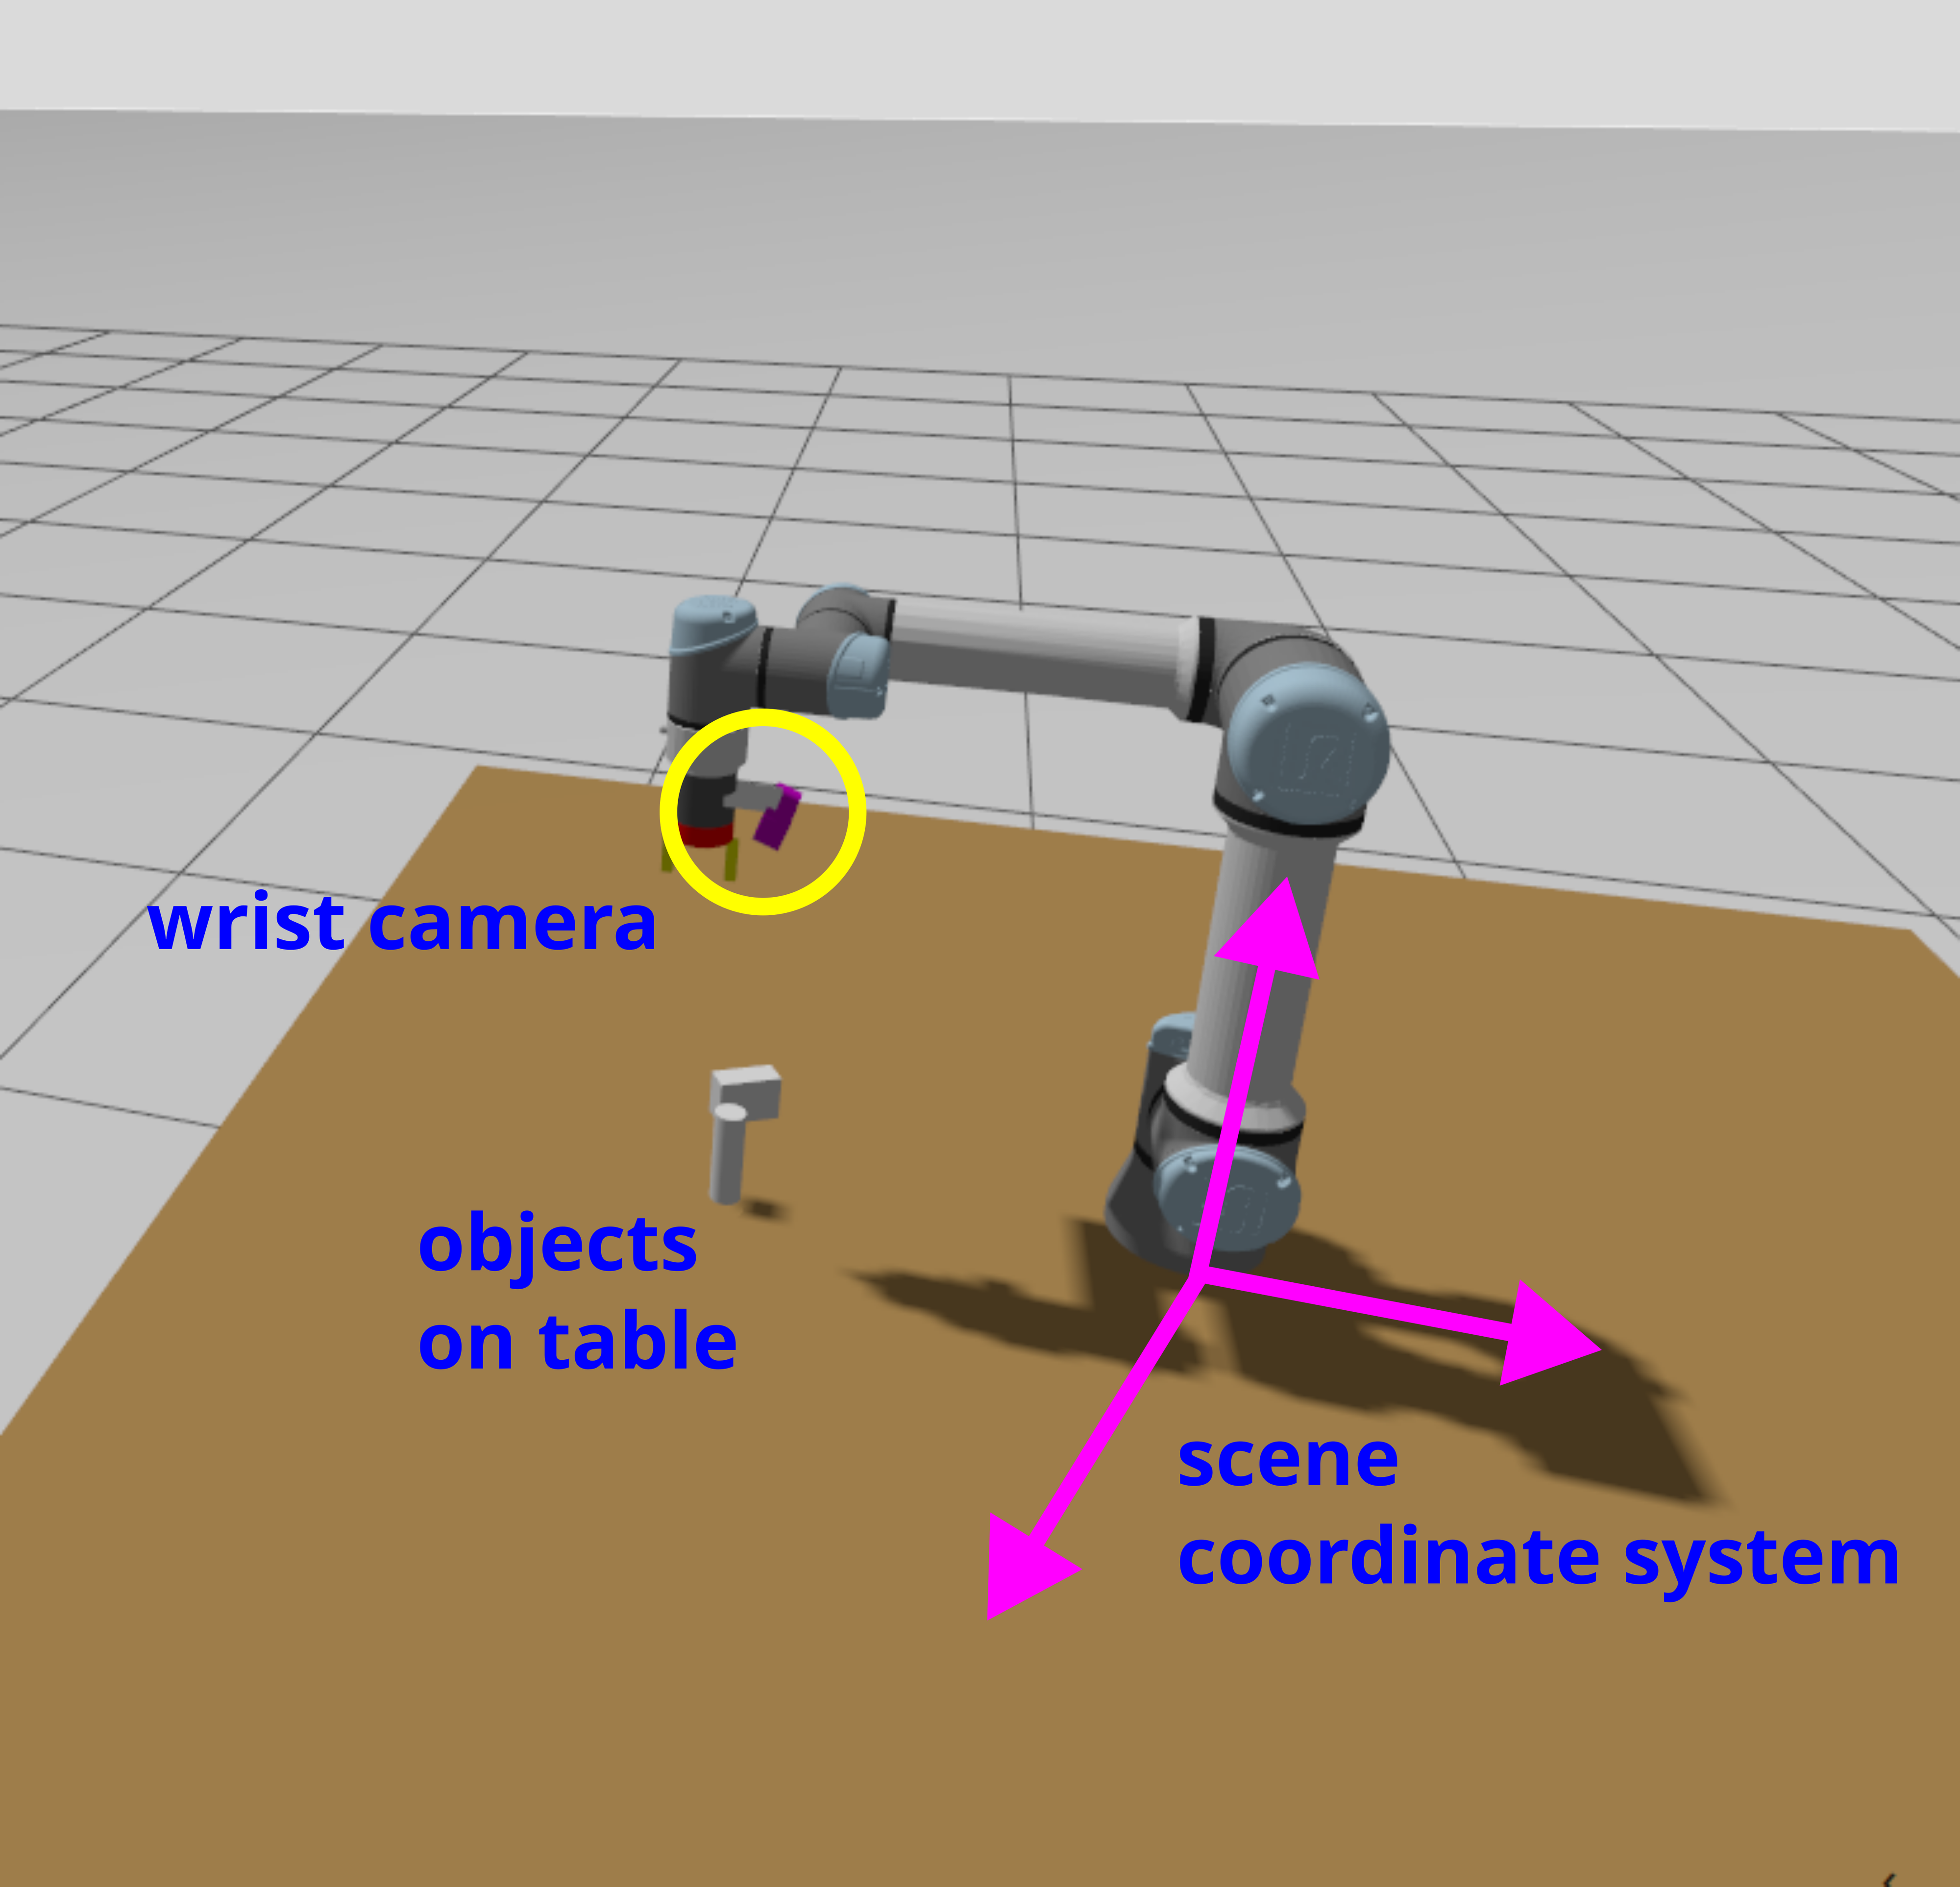
In this ROS2 and robotics tutorial, we explain
- How to create a combined model of a robot and a gripper and simulate the created model in ROS2.
- How to properly configure the MoveIt2 path planner and define the control groups such that the created model can be used for path planning and pick-and-place.
- How to create a Gazebo simulation and control the robot model in Gazebo using the MoveIt2 path planner.
- How to model a camera in ROS2 and Gazebo and how to record and visualize camera images as the robot moves in C++.
- How to implement a pinhole camera model for calculating scene coordinates from the camera images.
- How to implement a computer vision model in C++ and OpenCV for object recognition.
- How to use OpenCV to determine the object center and orientation.
- How to write C++ ROS2 MoveIt2 code to perform pick-and-place tasks.
- How to simulate pick-and-place tasks in Gazebo.
The YouTube tutorial is given here.